Configuring a Controller#
This tutorial walks you through configuring a Controller in VEXcode IQ (1st gen). By the end, you’ll have added a Controller and assigned it actions.
Note: The VEX IQ (1st gen) Brain and Controller each need a Radio Module installed in order to pair with each other.
Select the Devices tab.
Select Add a Device.
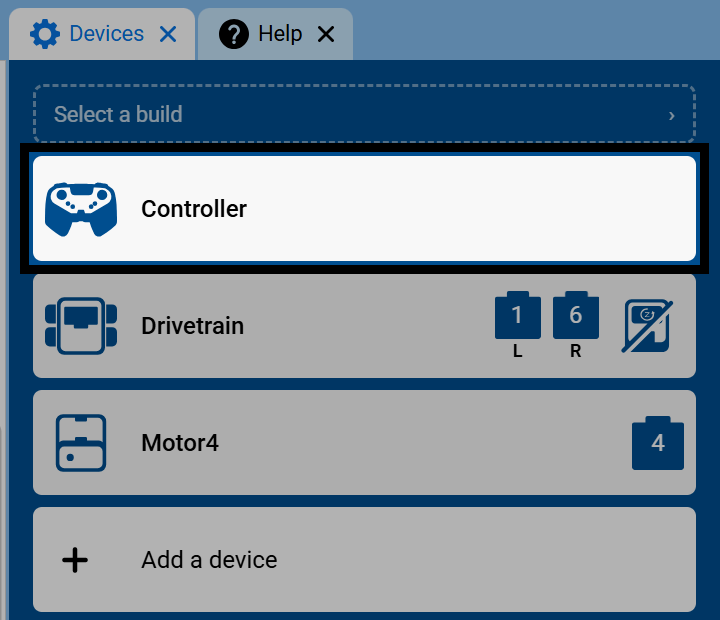
Select Controller.
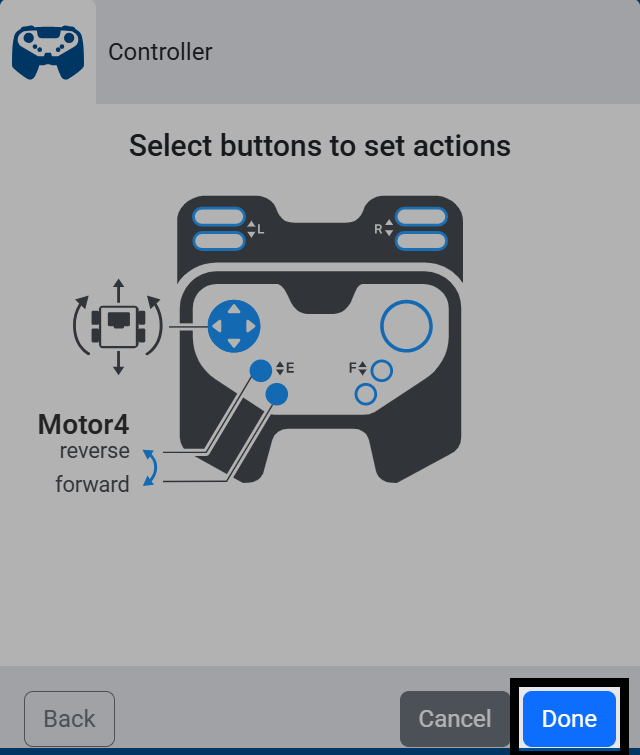
The Controller’s buttons and joysticks are shown, labeled by name. If you have a Drivetrain and/or Motor configured, you can assign controls for them here. These configured actions only run during a project while the controller enable/disable block has them enabled.
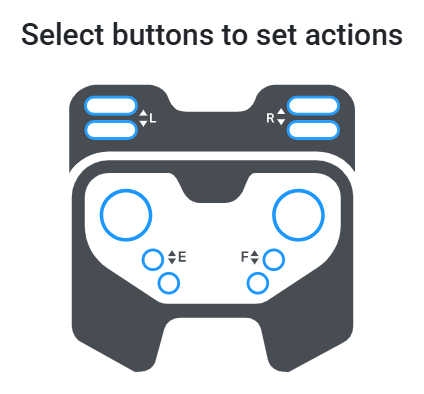
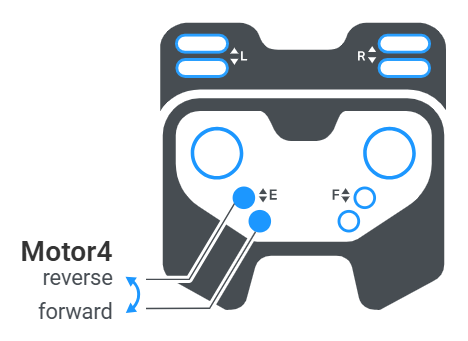
Select a button to choose which pair of buttons will control a motor — one button for the forward direction, and the other for reverse. If multiple motors are configured, both pairs of buttons can be selected at once.
If you have a Drivetrain configured, selecting a joystick toggles through different control schemes. See Configuring a Drivetrain if you haven’t added one yet.
Left Arcade — The left joystick controls both the Drivetrain’s forward and reverse movement and its turning.
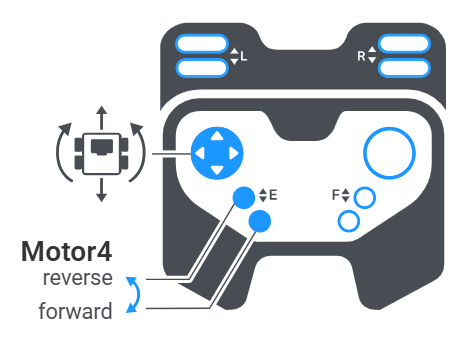
Right Arcade — The right joystick controls both the Drivetrain’s forward and reverse movement and its turning.
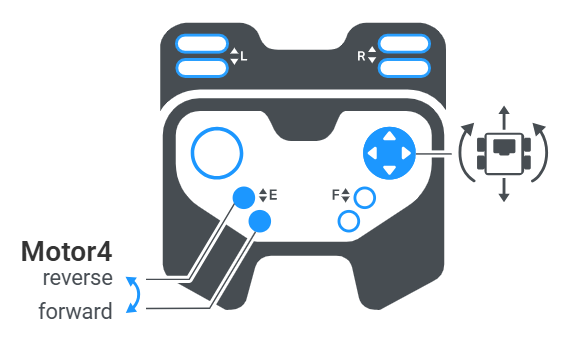
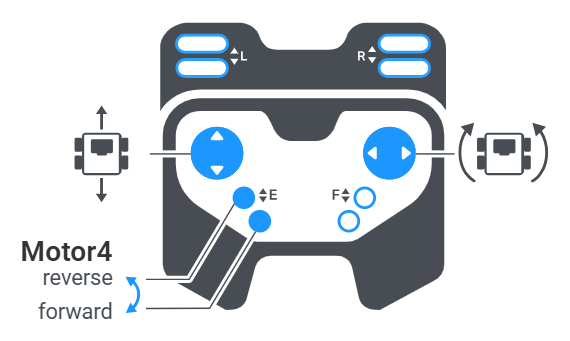
Split Arcade — One joystick controls the Drivetrain’s forward and reverse movement, while the other joystick controls turning.
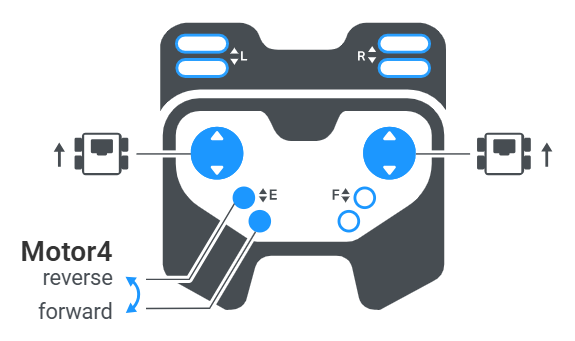
Tank Drive — The left joystick controls the left side of the Drivetrain, and the right joystick controls the right side, independently.
Select Done to add the Controller to your robot.
The Controller will now appear in your list of Devices.
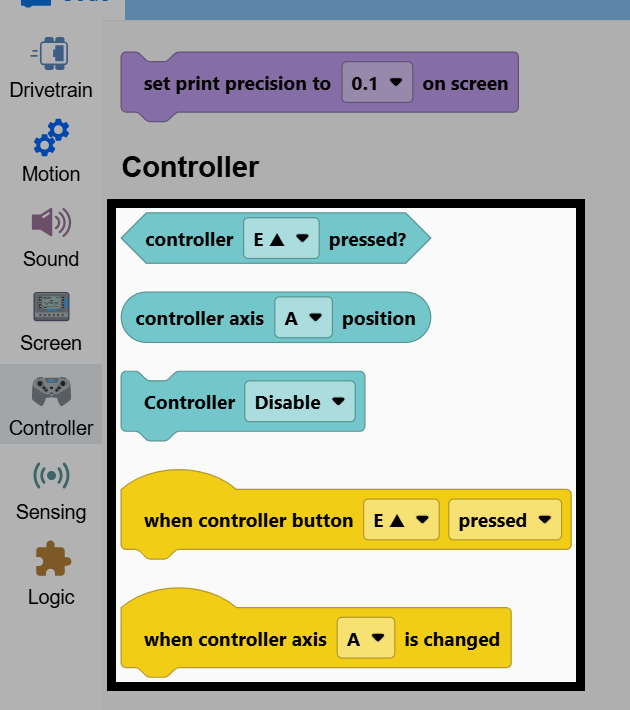
The Controller category will now appear in the toolbox, containing its blocks.