
控制#
简介#
Python 中的控制功能可以让你告诉机器人何时等待、何时重复操作、如何做出决定以及何时结束项目。
以下是所有控制指令的清单,包括方法和核心 Python 关键字:
wait–暂停程序一段时间。for–对序列中的每个项目重复代码。if–如果条件为true,则运行代码。if/else–根据条件运行不同的代码。if/elif/else–按顺序检查多个条件。while–条件为true时重复代码。break–立即退出循环。stop_program–结束正在运行的程序。pass–无需执行任何操作时使用占位符。
Wait#
wait 暂停一段特定的时间,然后转到下一行代码。
**用法: **wait(time, units)
参数 |
描述 |
|---|---|
|
等待时间,以正整数或小数表示。 |
|
表示时间的单位: |
# Move right for one second, then stop
robot.move_at(90)
wait(1, SECONDS)
robot.stop_all_movement()
For#
for 重复一组特定次数的操作。 for 可用于循环遍历列表、元组、字典、集合、字符串中的项目,或用于具有range的指定次数的循环。
Usage:
for value in expression_list:
    pass
参数 |
描述 |
|---|---|
|
存储迭代中的当前元素的临时变量。 |
|
循环遍历的元素集合(例如,列表、字符串、范围)。 |
# Move in a square path.
for index in range(4):
    robot.move_for(50, 0)
    robot.turn_for(RIGHT, 90)
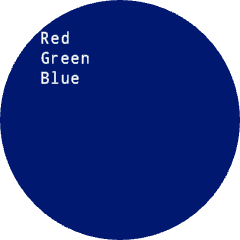
# Print each item in the list
colors = ["Red", "Green", "Blue"]

for color in colors:
    robot.screen.print(color)
    robot.screen.next_row()
If#
if 在条件为 True 时执行缩进的指令块。
用法:
if condition:
    pass
参数 |
描述 |
|---|---|
|
在语句运行时被检查的表达式或变量。如果为 |
# Kick when the screen is pressed
while True:
    if robot.screen.pressing():
        robot.kicker.kick(MEDIUM)
    wait(0.1, SECONDS)
If/Else#
if 和 else 根据条件为 True 还是 False,决定运行哪个缩进的指令块。
用法:
if condition:
    pass
else:
    pass
参数 |
描述 |
|---|---|
|
在语句运行时被检查的表达式或变量。如果为 |
# Show one emoji when the screen is pressed,
# and a different emoji when not pressed
while True:
    if robot.screen.pressing():
        robot.screen.show_emoji(EXCITED)

    else:
        robot.screen.show_emoji(BORED)

    wait(0.1, SECONDS)
If/Elif/Else#
if/elif/else 结构根据条件选择哪个缩进代码块运行:
如果条件为
if,True会运行其指令块。elif仅当之前所有条件均为False时,才检查其他条件。可以使用多个elif语句。else仅当之前没有任何条件为True时,才运行其指令块。
用法:
if condition:
    pass
elif condition:
    pass
else:
    pass
参数 |
描述 |
|---|---|
|
在语句运行时被检查的表达式或变量。第一个为 |
# Move the robot forward or reverse
# based on the position of the joystick
def when_axis_changed():
    position = controller.axis1.position()
    if position > 0:
        robot.move_at(0)
    elif position < 0:
        robot.move_at(180)
    else:
        robot.stop_all_movement()

controller.axis1.changed(when_axis_changed)
While#
while 只要条件为 True,就会重复运行代码。它也可以通过将条件设为 True 来像“永久循环”一样使用,或者通过在条件前添加 not 来像“等待直到”一样使用,如下方示例所示。
用法:
while condition:
    pass
参数 |
描述 |
|---|---|
|
在每次迭代前被检查的表达式或变量。如果为 |
# Keep the LEDs green while the robot is moving
robot.move_for(200, 0, wait=False)
while robot.is_move_active():
    robot.led.on(ALL_LEDS, GREEN)
    wait(50, MSEC)

robot.led.on(ALL_LEDS, BLACK)
while True:
    # Continually flash all LEDs red then green.
    robot.led.on(ALL_LEDS, RED)
    wait(0.5, SECONDS)
    robot.led.on(ALL_LEDS, GREEN)
    wait(0.5, SECONDS)
# Wait until the screen is pressed before
# turning off the LEDs
while not robot.screen.pressing():
    robot.led.on(ALL_LEDS, RED)
    wait(50, MSEC)

robot.led.on(ALL_LEDS, BLACK)
Break#
break 会立即退出循环。break 可用于跳出永久循环。
# Flash LEDs until the screen is pressed
while True:
    robot.led.on(ALL_LEDS, RED)
    wait(0.5, SECONDS)
    robot.led.on(ALL_LEDS, GREEN)
    wait(0.5, SECONDS)

    if robot.screen.pressing():
        break

# Turn the LEDs Off
robot.led.off(ALL_LEDS)
Stop Program#
stop_program ends a running project.
**用法: **robot.stop_program()
参数 |
描述 |
|---|---|
该方法没有参数。 |
# Stop the project once the screen is pressed
while True:
    robot.led.on(ALL_LEDS, RED)
    wait(0.5, SECONDS)
    robot.led.on(ALL_LEDS, GREEN)
    wait(0.5, SECONDS)
    if robot.screen.pressing():
        robot.stop_program()
Pass#
pass 是未来代码的占位符,可用于避免空循环、条件和函数中的错误。
if condition:
    pass
def function():
    pass