Κίνηση του βραχίονα#
Moving the Arm
This tutorial covers how to move the arm on your Clawbot IQ in VEXcode IQ (1st gen). By the end, you’ll have a project that raises the arm.
Make sure your robot is configured with the Drivetrain, Gyro version of the Clawbot IQ build, so you see the ClawMotor and ArmMotor blocks in the toolbox.
Attach the spin motor for block to the when started block.
The spin motor for block, spinning the ClawMotor by default.#
όταν ξεκινά
περιστροφή [ClawMotor v] [close v] για (90) [μοίρες v] ▶
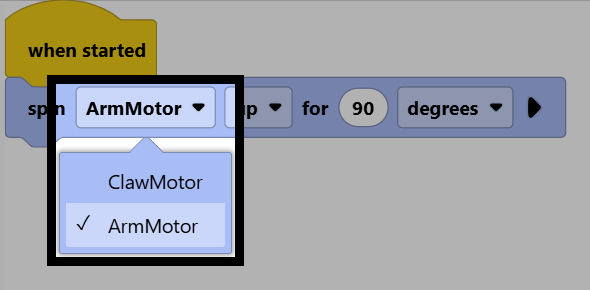
Change its motor parameter to ArmMotor, to control the arm.
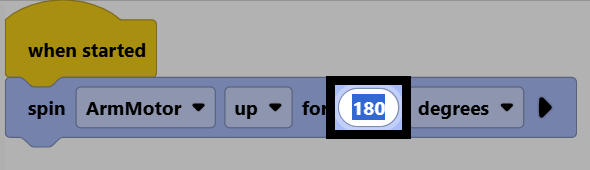
Change its distance parameter to 180, to move the arm 180 degrees from its current position.
Make sure your robot is connected to VEXcode, then select Download to download the project to the Brain.
Select Run to run the project. This project will now raise the arm up.