Mover la garra#
This tutorial covers how to move the claw on your Clawbot IQ in VEXcode IQ (1st gen). By the end, you’ll have a project that closes the claw, waits, then opens it again.
Make sure your robot is configured with the Drivetrain, Gyro version of the Clawbot IQ build, so you see the ClawMotor blocks in the toolbox.
Attach the spin motor for block to the when started block. This closes the claw.
cuando inicie
girar [ClawMotor v] [cerca v] por (90) [grados v] ▶
Attach a wait block below it, to pause before opening the claw again.
cuando inicie
girar [ClawMotor v] [cerca v] por (90) [grados v] ▶
esperar (1) segundos
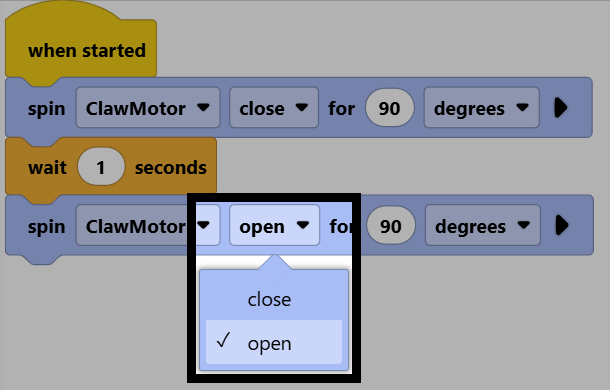
Attach another spin motor for block below the wait block.
cuando inicie
girar [ClawMotor v] [cerca v] por (90) [grados v] ▶
esperar (1) segundos
girar [ClawMotor v] [cerca v] por (90) [grados v] ▶
Change its direction parameter to open, to open the claw back up.
Make sure your robot is connected to VEXcode, then select Download to download the project to the Brain.
Select Run to run the project. This project will now close the claw, wait, then open it again.